Robot Control Taught by a Working Professional: From Simulation to Real Robot (SO-ARM101) Control

Master everything from implementing kinematics and dynamics theory with code written entirely from scratch, without open source, to communication interfaces for multi-joint manipulators.

(5.0) 1 reviews

19 learners

Level Intermediate

Course period Unlimited

Python
Python
robotics
robotics
robot
robot
kinematics
kinematics
inverse-kinematics
inverse-kinematics
Python
Python
robotics
robotics
robot
robot
kinematics
kinematics
inverse-kinematics
inverse-kinematics

What you will gain after the course

  • Hands-on Experience Portfolio: Controlling a Real Robot (SO-ARM101) with Code I Wrote Myself

  • Communication interfaces and porting capabilities: the ability to port simulation code to actual robot hardware

  • Low-level programming skills: Directly manipulate data (Read/Write) at servo motor register addresses

  • User-friendly GUI (Graphic User Interface) development capabilities: Enables users to intuitively and easily operate the actual robot (AO-ARM)

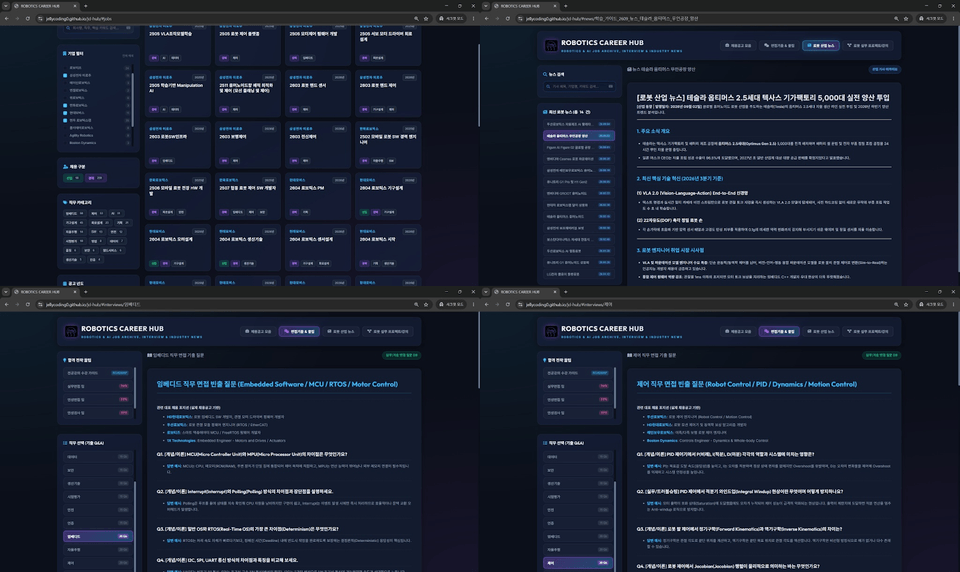
  • 300+ Job Postings (JDs) from Domestic and International Robotics Companies | Employment and Job Change Trend Analysis

  • Frequently asked and past control engineering interview questions, the latest news, and useful job-hunting tips provided

Robot Control Taught by a Working Professional: From Simulation to Real Robot (SO-ARM101) Control

Master everything from implementing kinematics and dynamics theory with code written entirely from scratch, without open source, to communication interfaces for multi-joint manipulators.

[Notice]

We are completely revamping (renewing) the curriculum and videos to provide you with a more up-to-date, polished course. (Through 10/31) You can continue taking the existing course as usual during the revamp, and you can also start learning the newly updated lessons right away at no additional cost., đồng thời có thể học ngay các bài giảng được cập nhật mới mà không phải trả thêm chi phí.

After completing the course,

  • Hands-on Experience Portfolio: Experience controlling a real robot (SO-ARM101) using code you wrote yourself

  • Communication interface and porting skills: The ability to port simulation code to actual robot hardware


  • Low-level programming skills: Directly read from and write data to servo motor register addresses

  • GUI (Graphic User Interface) development skills: Enable users to intuitively and easily operate the actual robot

  • Get a clear overview of employment and career-change trends: A collection of the latest domestic and international robotics control job postings (JDs) is provided.

Features of This Course

  • Rather than simply listing theory, this course shares the design methods and troubleshooting know-how actually used in the field.

  • Experience the entire robot development process by assembling, coding, and controlling a real robot (SO-ARM101) from the ground up.

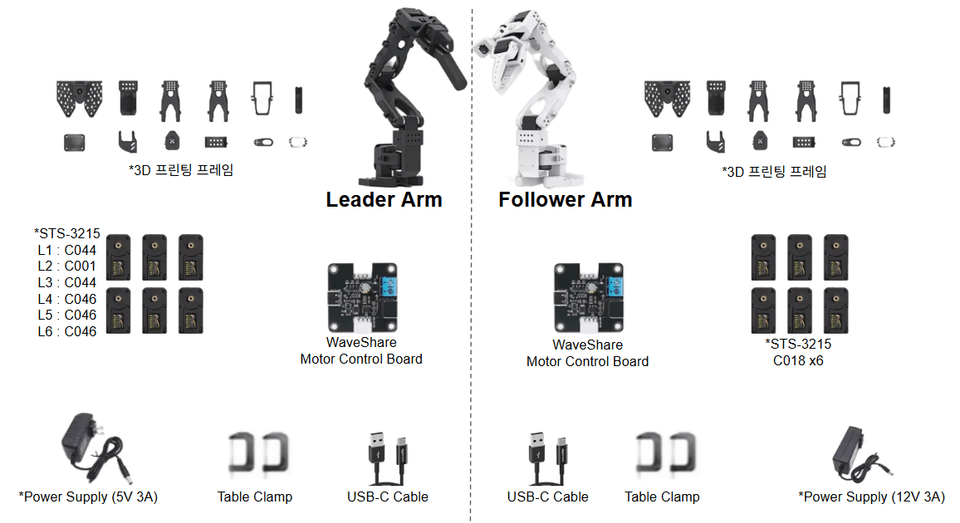
  • Practice with a cost-effective robot in the 300,000-won range, with the option to practice in a simulation environment even without a physical robot.

화면 캡처 2026-07-05 232649

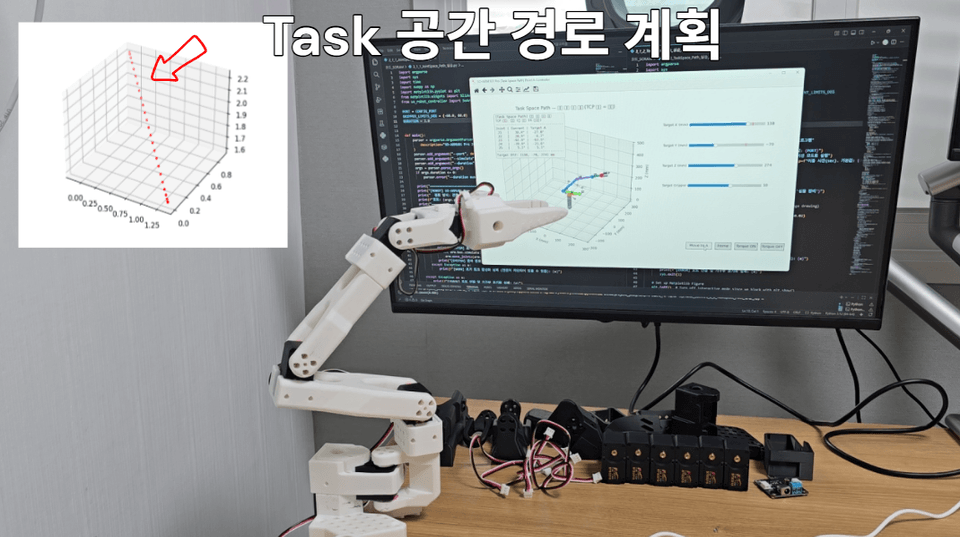
task_space_planning

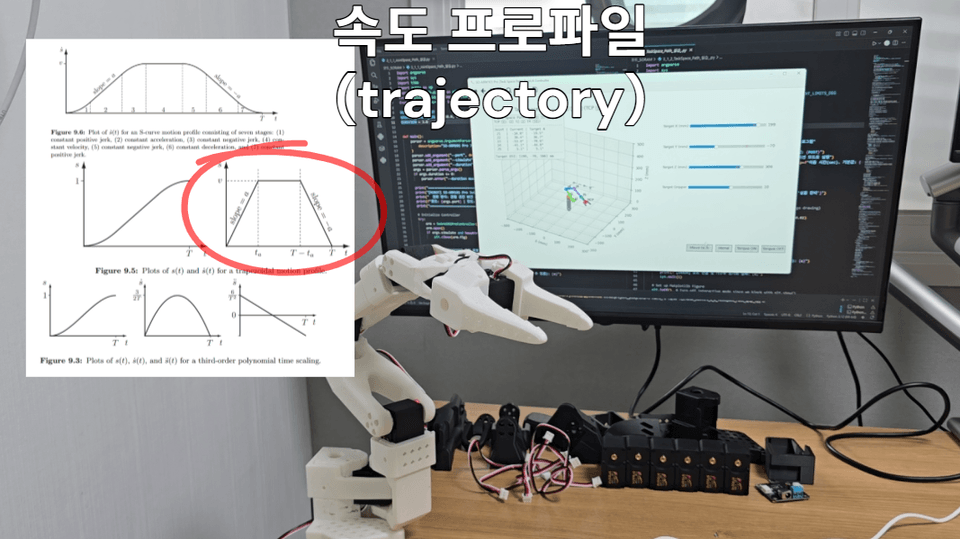
trajectory_profile


300+ domestic and international robotics company job postings (JDs) & frequently asked/past interview questions by position

Do you have any questions?

  • Q. Do I have to purchase the robot hardware (SO-ARM101)?

    • A. No, it is optional. The curriculum is designed so that you can fully practice through simulations without hardware. Still, since the SO-ARM isn't too expensive, we recommend purchasing the physical one and practicing with it yourself.

  • Q. Will it be difficult to take the course if I don't know ROS (Robot Operating System) or MuJoCo?

    • A. It is actually even better for those who are unfamiliar with them. This course does not teach you how to use the APIs of existing frameworks; instead, you will code the “core mathematics of robot control” hidden deep within those frameworks yourself. Even if you do not know ROS, as long as you have basic Python skills, you can build the control engine from the ground up.

  • Q. How does this help with job interviews or actual hardware development?

    • A. The candidates interviewers find most disappointing are those who have “barely managed to manipulate things by importing packages.” By completing this course, you will gain a thorough understanding of singularity avoidance and the forward/inverse loop computation structure of dynamics, giving the impression of “a genuine talent who has a deep grasp of the core principles of robotics.”

Notes Before Taking the Course

Practice Environment

  • Computer: Since the course focuses mainly on Python computations and lightweight physics simulations, you may use any environment, including Windows, Mac, or Linux. (Python 3.10 or later recommended)

  • Physical equipment: SO-ARM101 and a PC

Prerequisites and Important Notes

  • Basic Python syntax (experience with loops, conditionals, function definitions, and basic use of classes and objects)


  • Basic university-level mathematics and robotics knowledge (matrix multiplication, the concept of inverse matrices, very basic robotics kinematics, and an understanding of inverse-kinematics control will help you learn twice as fast.)

  • At the stage of interfacing with actual robot manipulator hardware, we will explain the necessary communication packet interface concepts one by one, starting from the basics and tailored to the Python level.


Recommended for
these people

Who is this course right for?

  • Job seekers or undergraduate students who want to get hired for robotics control/SW positions but feel their portfolios are lacking.

  • A junior developer frustrated by not knowing how the robot control engine actually works behind the library.

  • Those who want to go beyond on-screen simulations and directly control real robot hardware with their own code.

Need to know before starting?

  • Basic Python syntax (experience with loops, conditional statements, function definitions, and basic use of classes and objects)

  • Basic college-level math knowledge (reviewing matrix multiplication, the concept of inverse matrices, and only the most basic concepts of differentiation will double your speed of understanding).

  • The concept of the communication packet interface required during the actual hardware integration stage will be explained in the lecture and lecture materials.

Hello
This is jelly

Career Verified

91

Learners

8

Reviews

2

Answers

5.0

Rating

4

Courses

Hello, I’m a robotics developer at a global enterprise.

After working in the robotics and mobility industry for years, I have experienced everything from the hardware fundamentals to embedded systems and high-level software.


Based on the expertise I have diligently built in the field, I clearly explain what skills are truly needed in the industry.

Through projects that provide practical help with getting a job or changing jobs, I will help you grow into a standout robotics and mobility engineer..


If there’s anything you’re curious about in the course, feel free to leave a comment anytime. I’ll help you gain as much as possible so you feel the course fee was well worth it!

I’m cheering you on in your wonderful engineering journey.

More
Published: 
Last updated: 

Reviews

All

1 reviews

5.0

1 reviews

  • aceoftop1975님의 프로필 이미지
    aceoftop1975

    Reviews 134

    Average Rating 5.0

    5

    100% enrolled

    ===== 26/09/21/Mon 15:50 ===== Thank you for providing so much information about getting into robotics. After listening to all of jelly’s lectures, I feel I have a much better idea of what else I need to study and what equipment I need to pursue robotics. I learned many new things, including detailed explanations of the terminology. Thank you for creating such excellent lectures.

    Similar courses

    Explore other courses in the same field!

    Limited time deal ends in 7 days

    $84,700.00

    30%

    $93.50